Skip to content
Research projects
AIMS5.0The crises of recent years have shown how vulnerable long supply chains are. AIMS5.0 (Artificial Intelligence in Manufacturing leading to Sustainability and Industry5.0) aims to …
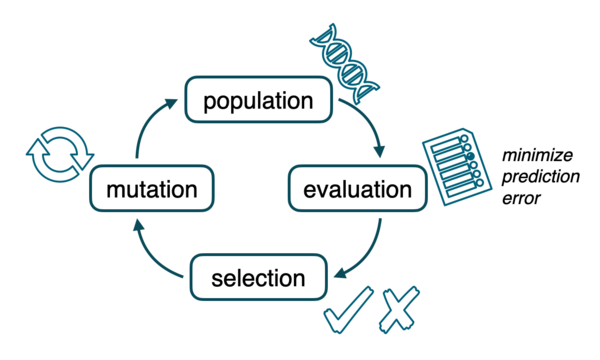 Collective Behaviors by Minimize SurpriseGenerating collective behaviors by minimizing surprise and maximizing prediction success Similarly to evolving controllers for single robots also controllers for groups of robots …
 DI-OSVISEAnyone who designs a chip has to check that it does what it should. This verification today mostly needs expensive proprietary tools. DI-OSVISE (open-source design tools for the …
 FOCALQuantum computers will one day be able to break the encryption that secure communication relies on today. The answer is post-quantum cryptography (PQC). So far, though, it works …
 ISOLDERISC-V is an open instruction set architecture: anyone may build processors for it, without licence fees and without depending on a single vendor. ISOLDE (High Performance, Safe, …
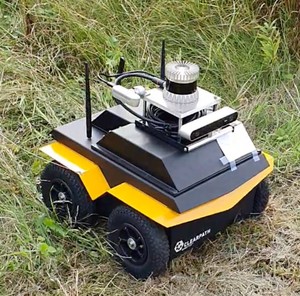 Outdoor Multi-Robot SystemKicking swarm robots out of the lab One of the most important challenges in swarm robotics is to move on and push the frontier to large robot teams operating outdoors. Large auto …
 RigolettoWith electrification and automated driving, the software in vehicles is growing fast, to an estimated billion lines of code by 2030. The established architecture of many separate …
 RILKOSANMotivation and objectives: Due to the increasing digital networking in business and society, digital infrastructures are becoming ever more complex and thus offer new targets for …
Shift2SDVIn the software-defined vehicle, new functions no longer arrive with a new control unit but as a software update over the air. Shift2SDV builds a shared European basis for this: …
SSVEKIPedestrians, cyclists and other vulnerable road users have hardly any protection when a vehicle hits them. SSVEKI develops a system that foresees such collisions in real time and …
TEdgeAIAI chips for edge devices have to compute efficiently and at the same time be trustworthy and resistant to attacks. That is hard: design flow, tools and AI model have to fit toge …
Completed projects (58)
 A-IQ ReadyArtificial Intelligence using Quantum measured Information for realtime distributed systems at the edge
AnoMedClinical care and smart devices produce more and more sensitive medical data. Artificial intelligence and big-data methods could turn them into more precise medicine, but only if …
 Arrowhead ToolsArrowhead Tools for Engineering of Digitalisation Solutions
ASAMASAM targets a uniform process of automatic architecture synthesis and application mapping for heterogeneous multi-processor embedded systems based on adaptable and extendable AS …
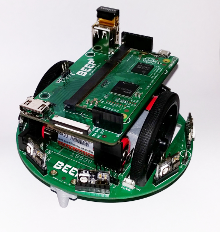 BEEPBEEP small mobile robot
 CeCaSHighly automated vehicles must process huge amounts of sensor data in real time. CeCaS (Central Car Server – Supercomputing for Automotive) developed a supercomputing platform fo …
CFDPDevelopment of the CCSDS File Delivery Protocol IP Core
 Chrono PilotModulating Human Subjective Time Experience
 CONETCONET, the Cooperating Objects Network of Excellence, is an EU-funded project that aims at fostering a European research community in the emerging domain of cooperating objects, …
 DAISDistributed Artificial Intelligent Systems
DLR Spacebot CupDLR SpaceBot Cup – Space Terrain Exploring Vehicle (STEVE)
 EdgeAIThe EdgeAI project ensures that Europe has the necessary tools, skills, and technologies to strengthen its edge AI design and development capabilities. By enhancing AI-based elec …
EEmotionDriver assistance and automated driving need vehicle dynamics control that is safe, fast and economical. EEmotion (Embedded Excellence – vehicle dynamics with AI) studied how to …
EFMCEfficient Programming Model for Future Many-Core System
EMC2Embedded Multi-Core Systems for Mixed Criticality Applications in Dynamic and Changeable Real-Time Environments
 EMDriveFuture vehicles spread their computing work over a network of sensors, control units and central computers. EMDrive (platform concept for distributed heterogeneous automotive rea …
 flora roboticaFlora Robotica: Societies of Symbiotic Robot-Plant Bio-Hybrids as Social Architectural Artifacts
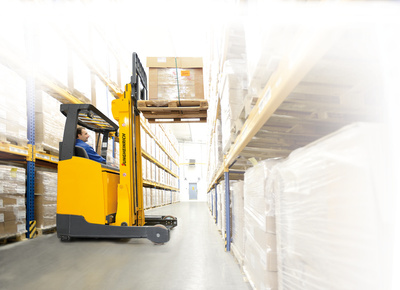 FTF out-of-the-boxFTF out-of-the-boxDas Forschungsprojekt "FTF out-of-the-box" beschäftigt sich mit der Entwicklung interaktiver, fahrerloser Transportfahrzeuge (FTF) für den Einsatz in Lagerumgeb …
 HANSE<div><div><div>00</div><img alt="" src="https://www.iti.uni-luebeck.de/typo3temp/pics/hanse_6_6ff545d092.jpg"/></div></div> 00 Overview
 iBASTiBAST - instantaneous Bridge Assessment based on Sensor Network Technology
 Inflammation at InterfacesExzellenzcluster "Entzündung an Grenzflächen" / Cluster of Excellence "Inflammation at Interfaces" (EXC 306)
 IoEInternet of Energy for Electric Mobility
 KI-IoTEntwicklungsplattform für vertrauenswürdige IoT-Mikrochips mit innovativem KI-Co-Prozessor
 KI-PROEnergieeffiziente Datenverarbeitung im autonomen Fahrzeug mittels Mehrprozessorsystem und integrierten KI-Beschleunigern
MacSpaceHigh-Performance ManyCore Rad-Hard DSP for Computation-Intensive Space Applications
 makeSensemakeSense: Easy Programming of Integrated Wireless Sensor Networks
 MARSMarine Robotics Simulator
 MAUSMobiles Autonomes Unterwasser System
 MeteracomMetrology for THz Communications (DFG Research Unit FOR 2863)
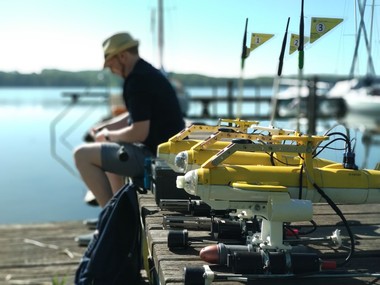 MONSUNMONSUN – swarm-capable micro AUV (Autonomous Underwater Vehicle)
 MOVEMonitoring von Vegetation und Wasserqualität in Seen mit Unterwasser-RoboterschwärmenMotivationDie Flora und Fauna in Seen und Flüssen sind durch den Einfluss des Menschen stark …
 mReSm·ReS - modulares Rehabilitationssystem zum Training von Handfunktionen nach Schlaganfall
 NeptuneNeptun underwater robot
 NEUPANew explainability supported by world models for predictions in autonomous driving NEUPA will help increase the explainability of artificial neural networks (ANN) and enable thei …
 Organic ComputingSPP 1183, Subproject: Organic Fault-tolerant control Architecture for Robotic Applications
 Posenbestimmung für die Mensch-Roboter InteraktionPosenbestimmung für die Mensch-Roboter-Interaktion
Productive4.0Funded by ECSEL JU (EU Horizon 2020 plus national authorities), Horizon 2020 / ECSEL JU (ECSEL-2016-2), grant 737459.
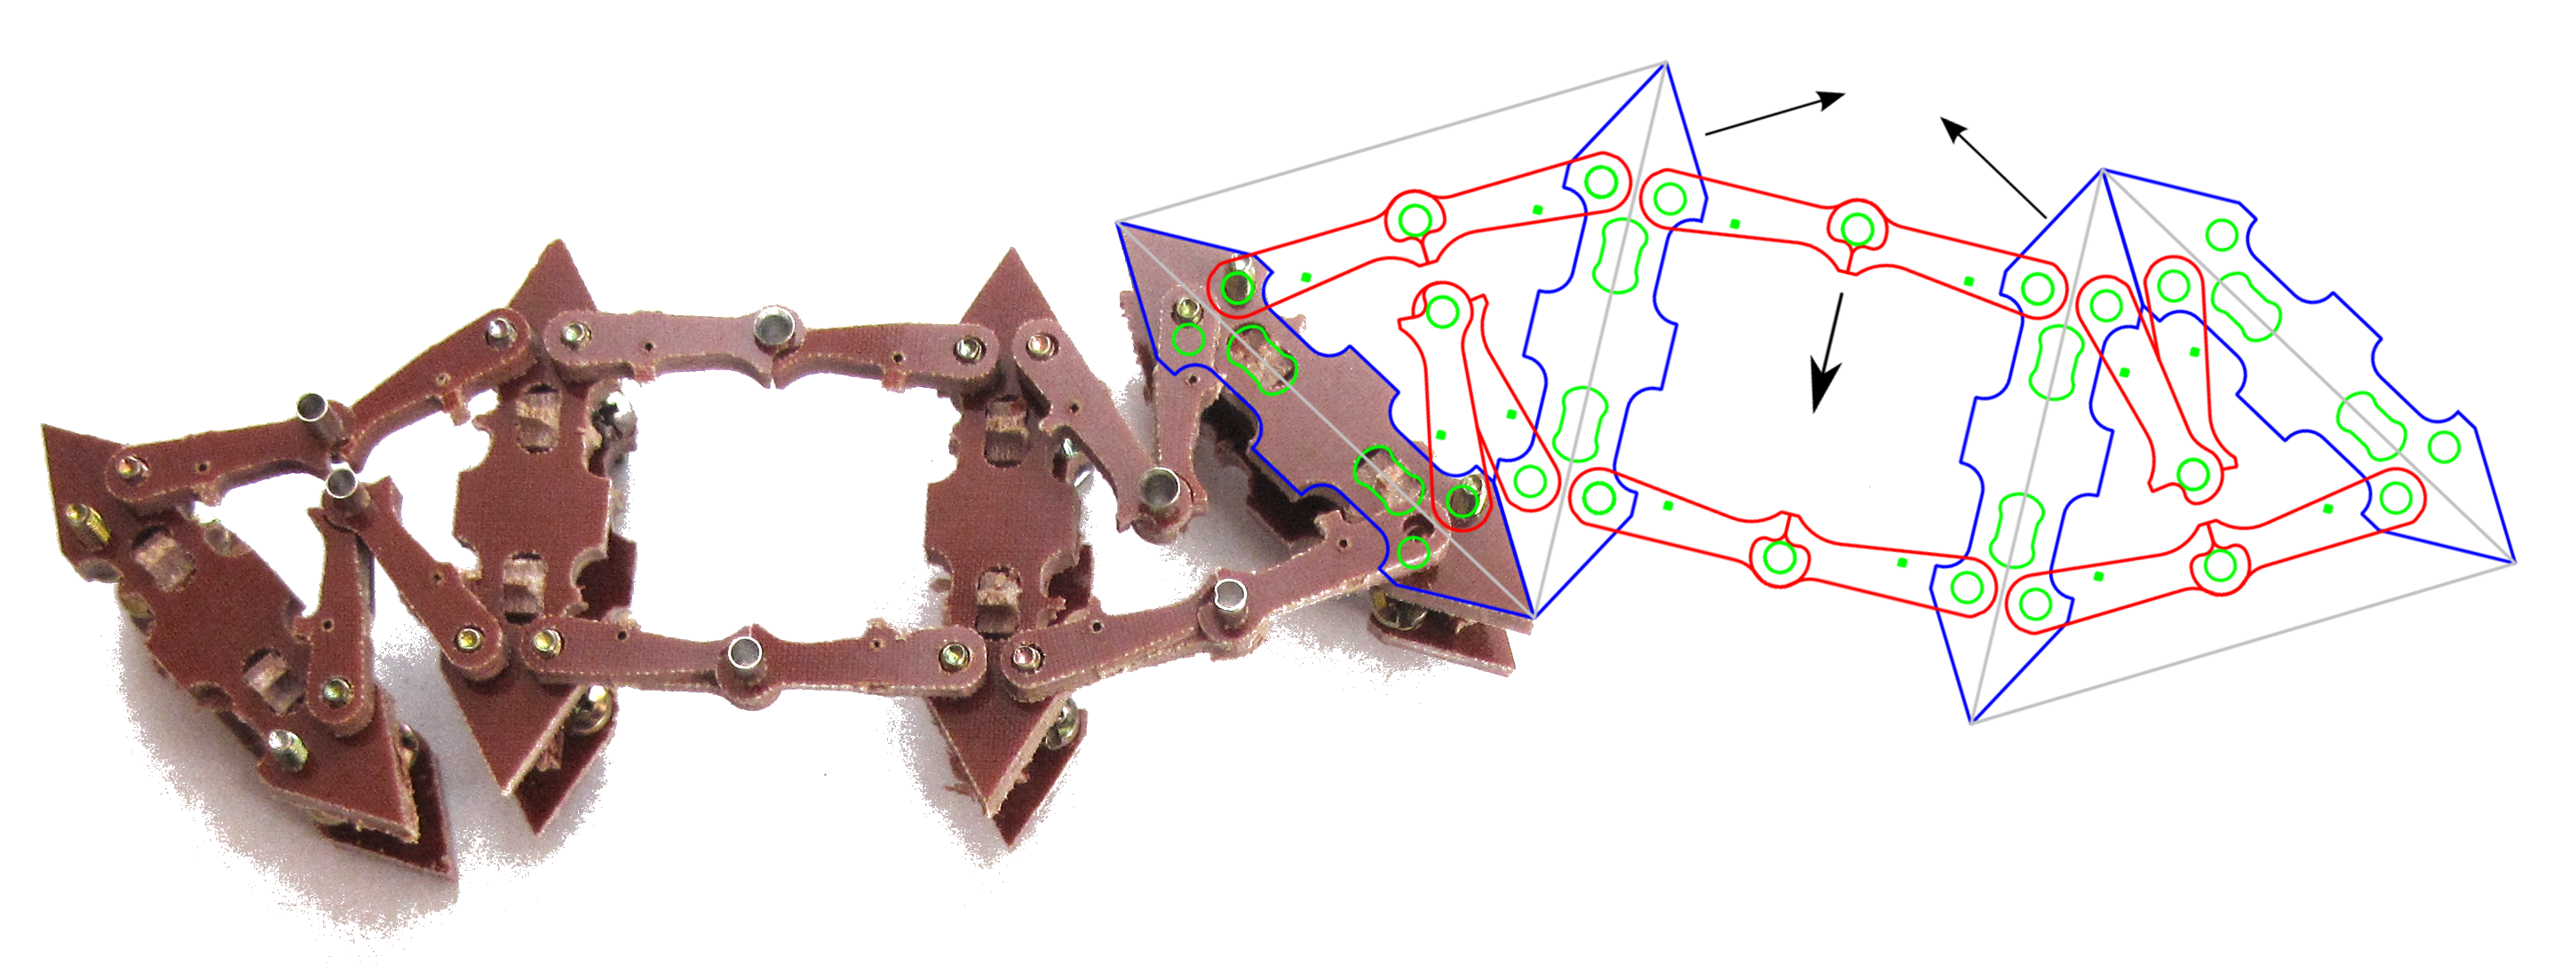 Programmierbare MaterieProgrammierbare Materie / Programmable Matter
QI2SQuick Image Interpretation System
R3-COPResilient Reasoning Robotic Co-operating Systems
R5-COPReconfigurable ROS-based Resilient Reasoning Robotic Cooperating Systems
 Real-World G-LABReal-World G-Lab: Integrating Wireless Sensor Networks with the Future Internet
 RELYonITResearch by Experimentation for Dependability on the Internet of Things
S3NETSatellite Swarm Sensor Network (S3NET) is a 2.5-year H2020 project coordinated by iTUBS that started 1st May 2016. Its consortium gathers 8 partners from 4 countries for a global …
S4PROSmart and Scalable Satellite High-Speed Processing chain (S4Pro) is a 3-year H2020 project coordinated by iTUBS that started 1st November 2018. Its consortium gathers 7 partners …
 SASVIIn a modern system, a single weakness in any hardware or software layer can compromise the whole, and networking in the Internet of Things and Industry 4.0 enlarges the attack su …
 SEMBIO AUVSEMBIO - a small energy-efficient swarm AUV
SILGENTASMore and more devices in the home are connected to the internet, yet IT security is often skimped on. SILGENTAS (Security in the intelligent networked home) aims to improve the s …
 SILKOSTU
 SMART-ESMART-E underwater robot platform
 SoCRocketSoCRocket – Transaction-Level Modeling Framework for Space Applications
 SPITFIRESemantic-Service Provisioning for the Internet of Things using Future Internet Research by Experimentation
 SURFER<div><div><div>00</div><img alt="" src="https://www.iti.uni-luebeck.de/typo3temp/pics/surfer3_3d18fb84ae.jpg"/></div></div> 00 Overview
 TwinSpaceThe aim of the lighthouse project is to spread the hinge function of digital technologies between economic and ecological benefits. Specifically, this is to be achieved by optimi …
 VE-JupiterEindeutige Identifizierbarkeit für vertrauenswürdige Mikroelektronik mit Chiplets
 Visual NavigationVisual Navigation / Visual SLAM for industrial mobile robots
 WatchPlantSmart Biohybrid Phyto-organisms for Environmental In Situ Monitoring
WiHMoWireless Health Monitoring